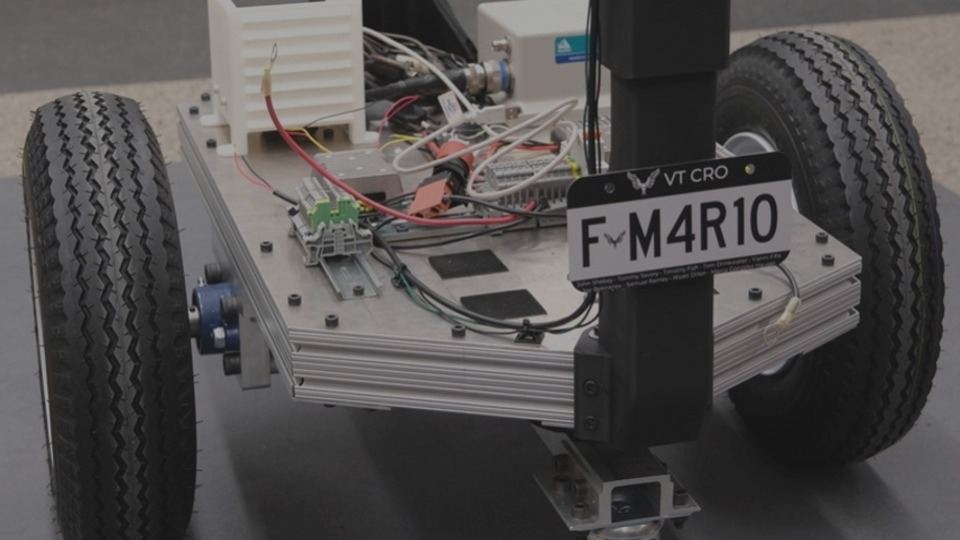
AutoNav rover with its VT CRO license plate

NAV

AutoNav

Autonomous rover project built to tackle real outdoor obstacle courses in the IGVC competition.

About AutoNav

AutoNav is all about pushing the limits of real-world autonomy. Competing in the Intelligent Ground Vehicle Competition (IGVC), we design, build, and program a completely autonomous rover capable of navigating complex outdoor obstacle courses.

AutoNav is an MDE team and restricted to Juniors and Seniors only.

The AutoNav team

Leadership

  • Manan Sharma

    Chief Engineer

    Spring 2027

Members

  • Barrett Larson

    Spring 2027

  • Dang Zehao

    Spring 2027

  • Ethan Xu

    Spring 2027

  • Evan Cedar

    Spring 2027

  • Jacob Lorenz

    Spring 2027

  • Kirill Romanov

    Spring 2028

  • Levi Malone

    Spring 2027

  • Neal Mehta

    Spring 2028

  • Samridh Mankala

    Spring 2030